Drone Control Board Development
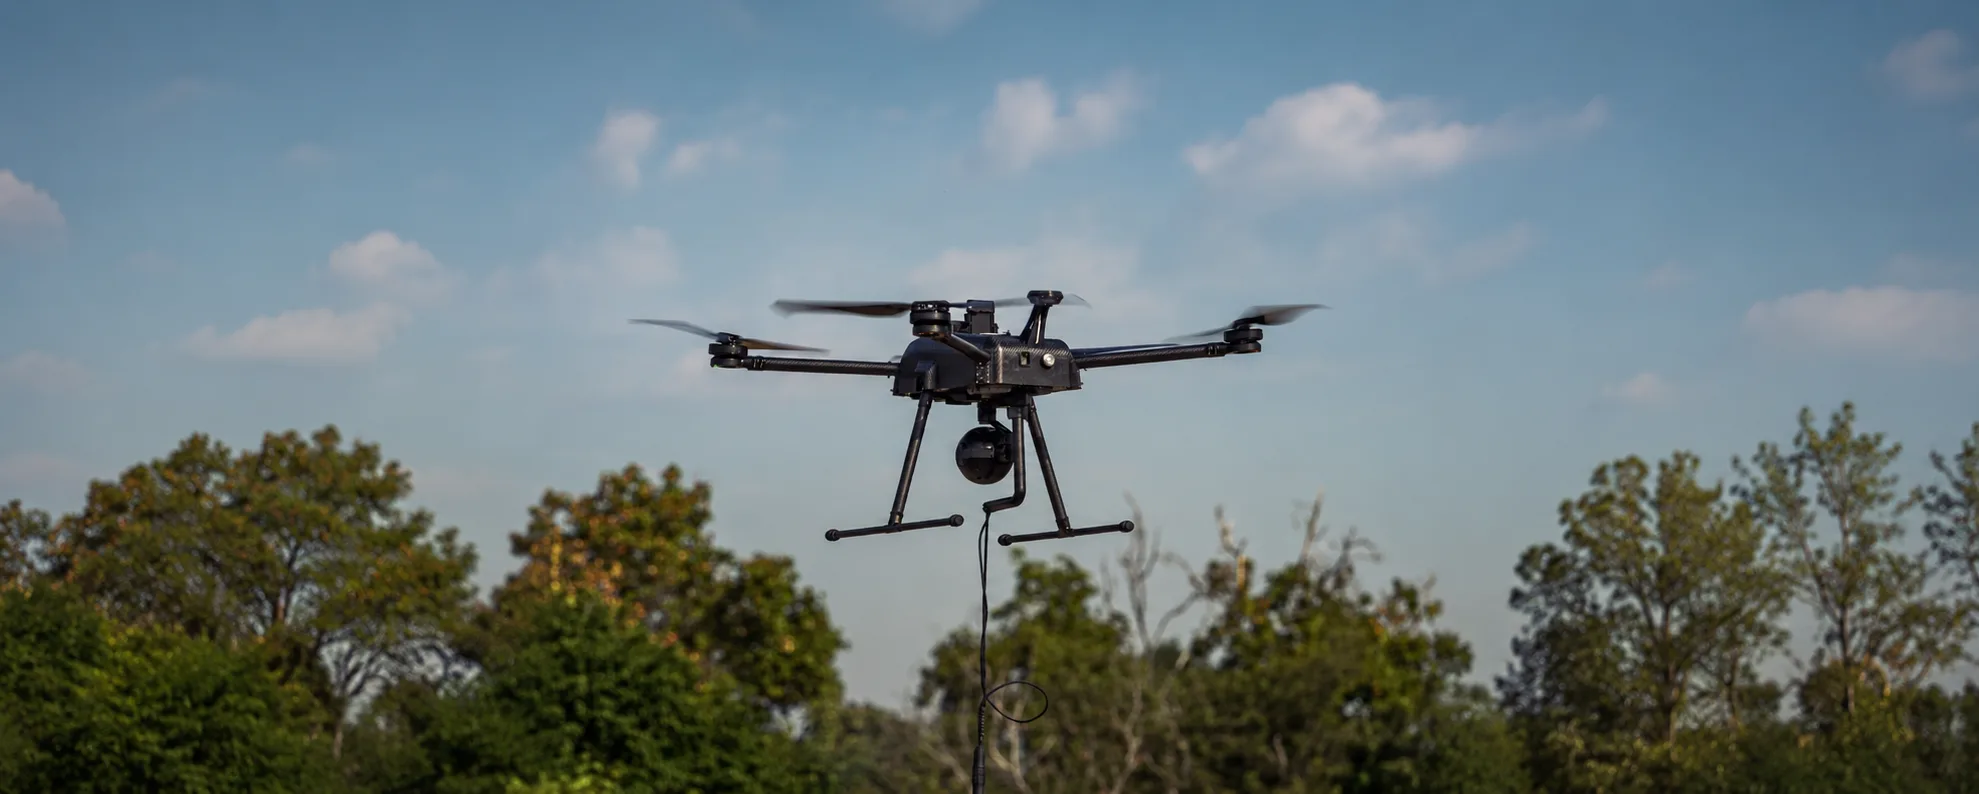
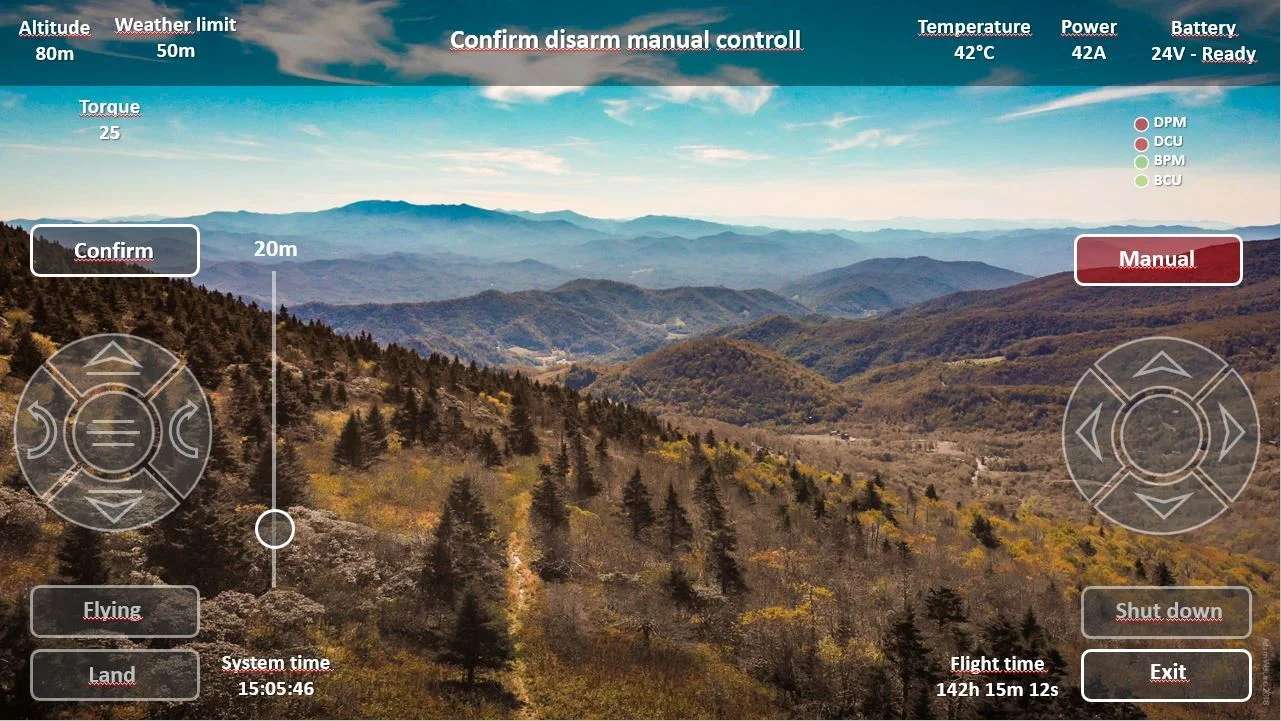
We designed and developed a custom flight control board built around the STM32F4 microcontroller, deeply integrated with the Pixhawk flight system. The platform delivers reliable, low-latency drone maneuvering through a primary UART control channel and a fully independent PPM fallback, ensuring the UAV stays in control even when the unexpected happens.
Category:
AerospaceIndustry:
Aerospace & UAVClient:
UAV / Aerospace PartnerYear:
2023The Challenge
Drone flight systems are inherently safety-critical, yet most embedded control architectures rely on a single communication channel. A UART link failure, signal interference, or timing glitch can result in loss of control mid-flight, with no recovery path. The challenge was to design a control board that provides real-time command execution over UART while guaranteeing automatic failover to an independent PPM channel with zero pilot intervention.
Our Solution
We built a redundant flight control architecture using an STM32F4 microcontroller as the central command hub, interfaced with Pixhawk via UART as the primary control path. A second, fully independent PPM (Pulse Position Modulation) channel, generated by two hardware general-purpose timers, serves as the failsafe backup. Redundancy logic continuously monitors the primary link and switches to PPM automatically if UART is interrupted. The system is compatible with both Pixhawk and Ardupilot ecosystems and was validated under simulated failure conditions to confirm stable control handover and low-latency response.
Key Features
- Dual-Channel Control Architecture: UART as the primary command interface paired with hardware-timer-driven PPM fallback: two completely independent paths for maximum reliability.
- Automatic Failsafe Switchover: Redundancy logic detects UART link loss and switches to PPM without pilot action, maintaining full flight authority during the transition.
- STM32F4 Real-Time Performance: High-performance Cortex-M4 MCU ensures deterministic, low-latency command processing critical for stable UAV maneuvering.
- Pixhawk & Ardupilot Integration: Seamless integration with the industry-standard Pixhawk flight stack and Ardupilot firmware, maximizing ecosystem compatibility.
- Validated Under Failure Conditions: Tested across multiple flight scenarios with simulated primary channel failures: confirming stable handover, consistent pulse timing, and precise response.
Technologies
- STM32F4
- Pixhawk
- Ardupilot
- UART
- PPM
- FreeRTOS
- C
- HAL
Results
The completed platform delivered reliable, real-time drone control with automatic fail-safe operation, proving that embedded redundancy can be implemented cleanly on cost-effective microcontroller hardware. The architecture is reusable as a foundation for next-generation UAV control systems requiring aerospace-grade reliability.
Work With Us
Ready to Build Something Exceptional?
From Edge AI inference to production firmware, we turn complex embedded challenges into real, deployable solutions. Let's talk.
